Robotic Arm Project
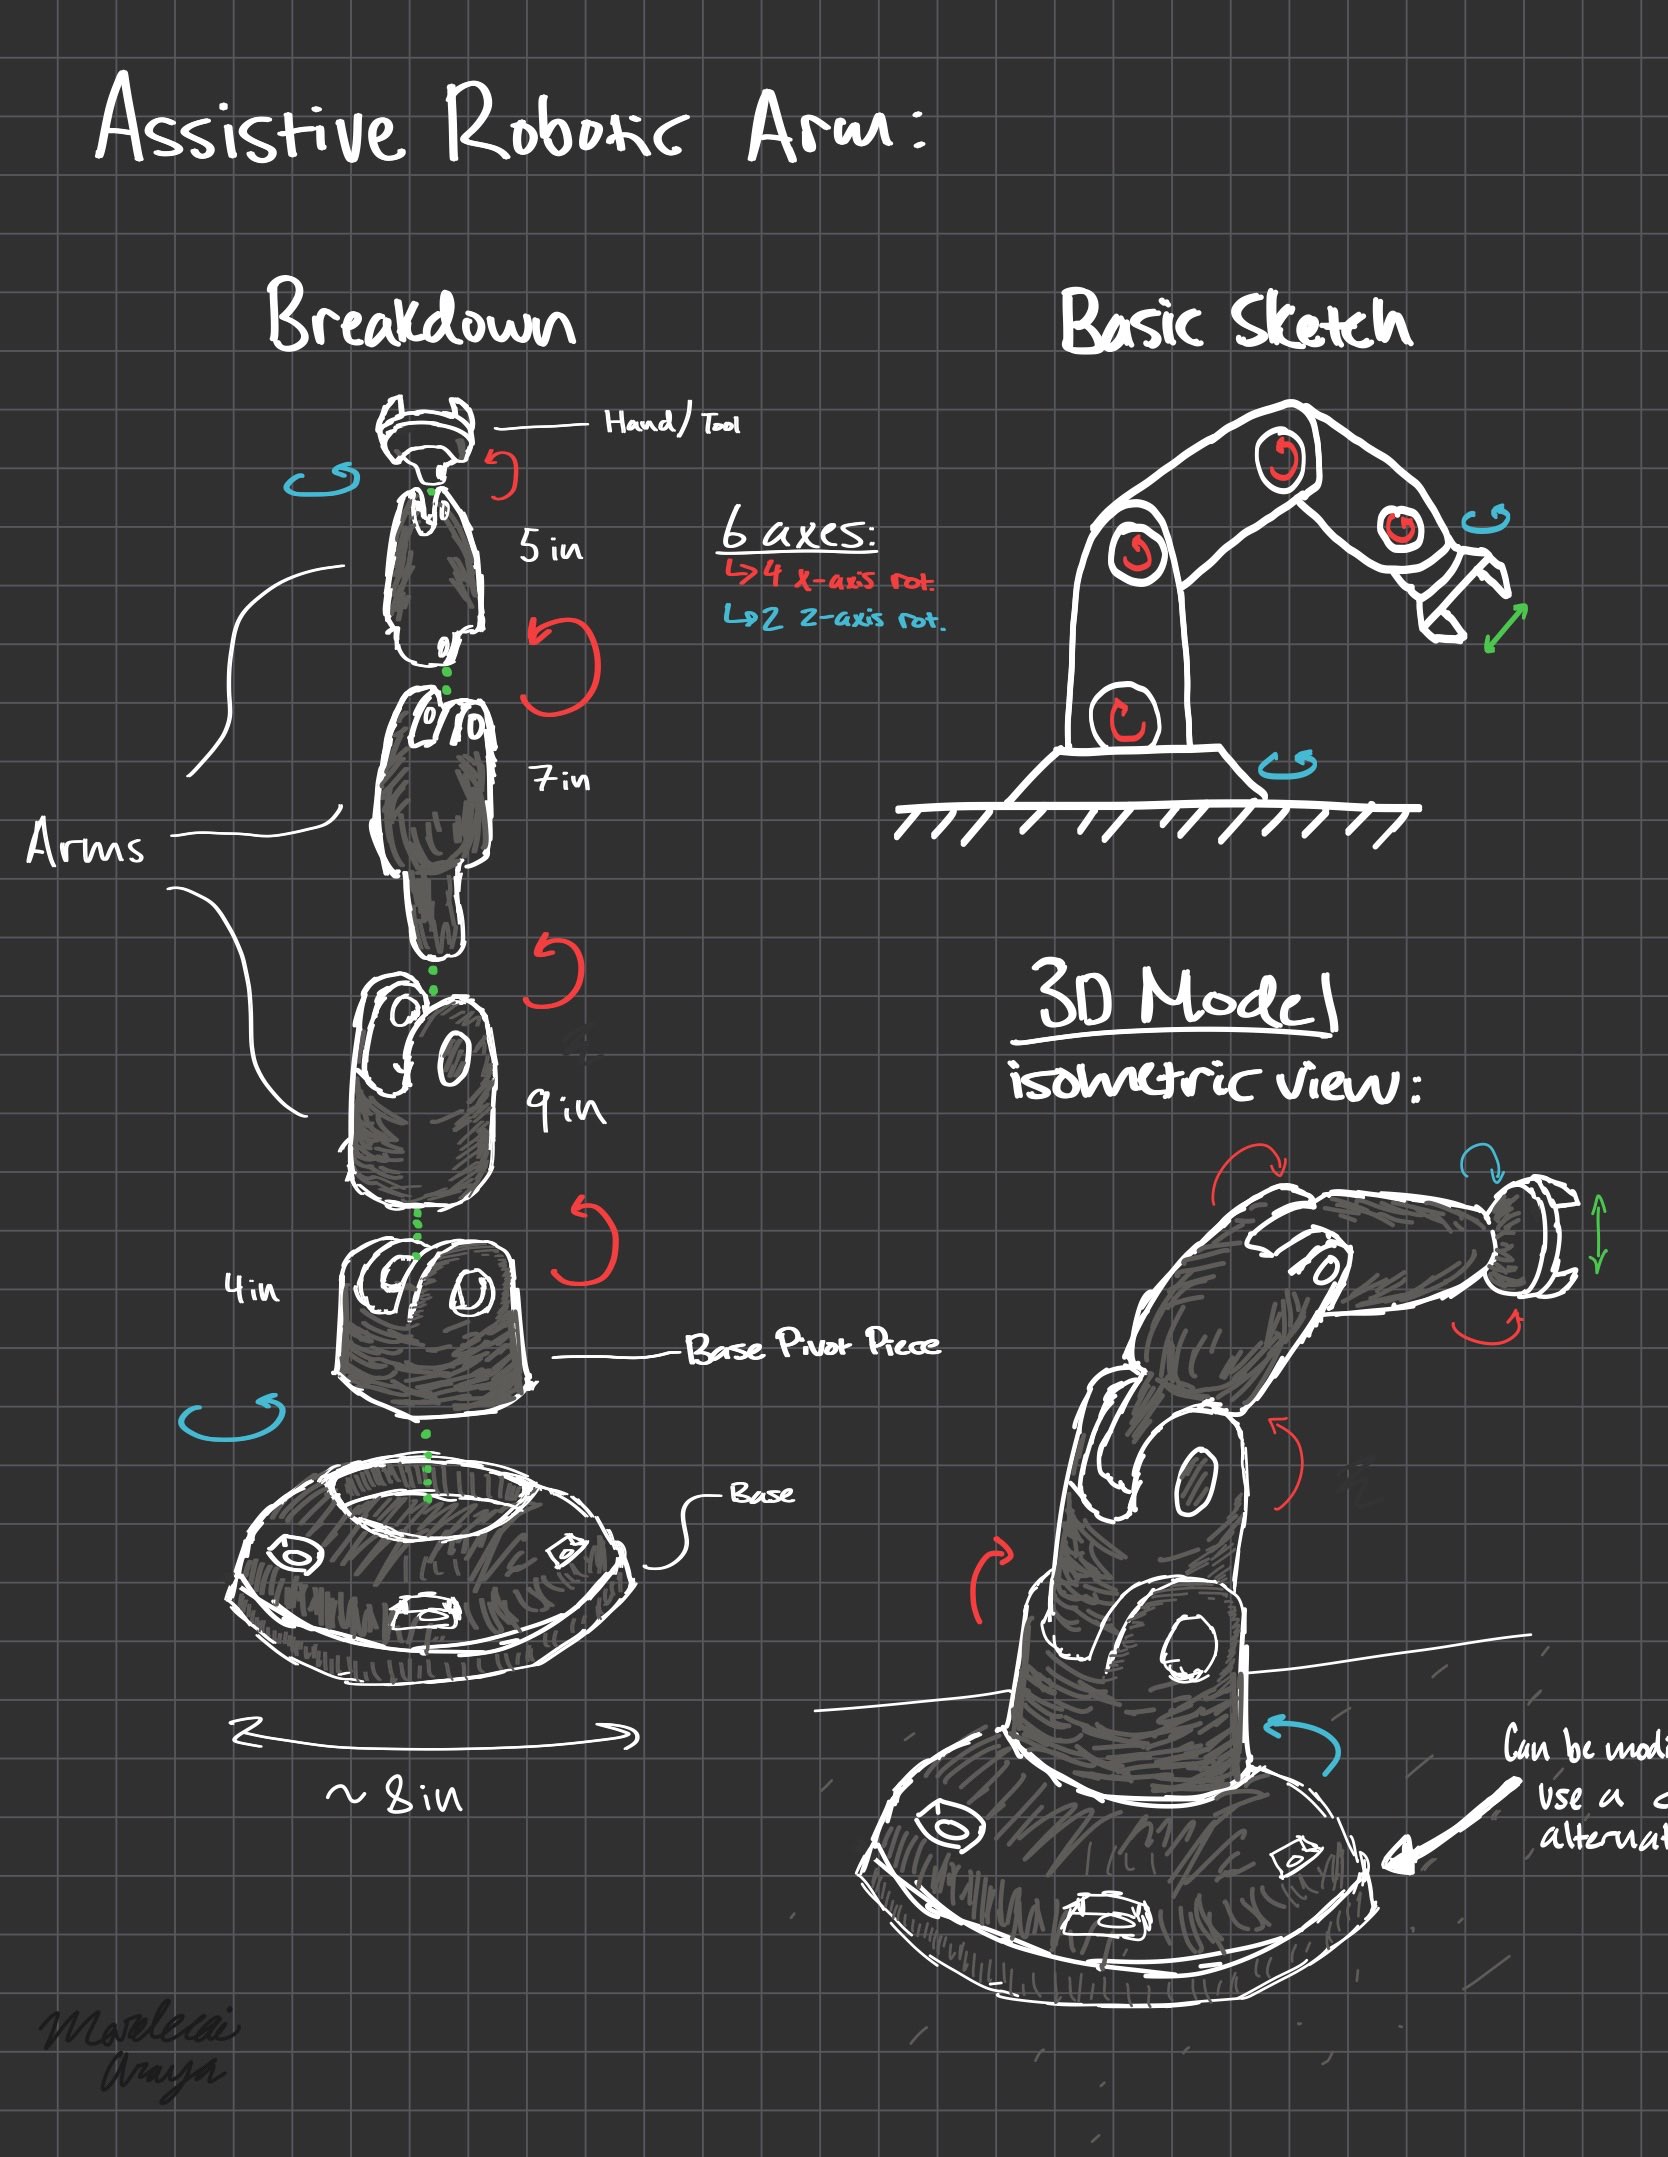
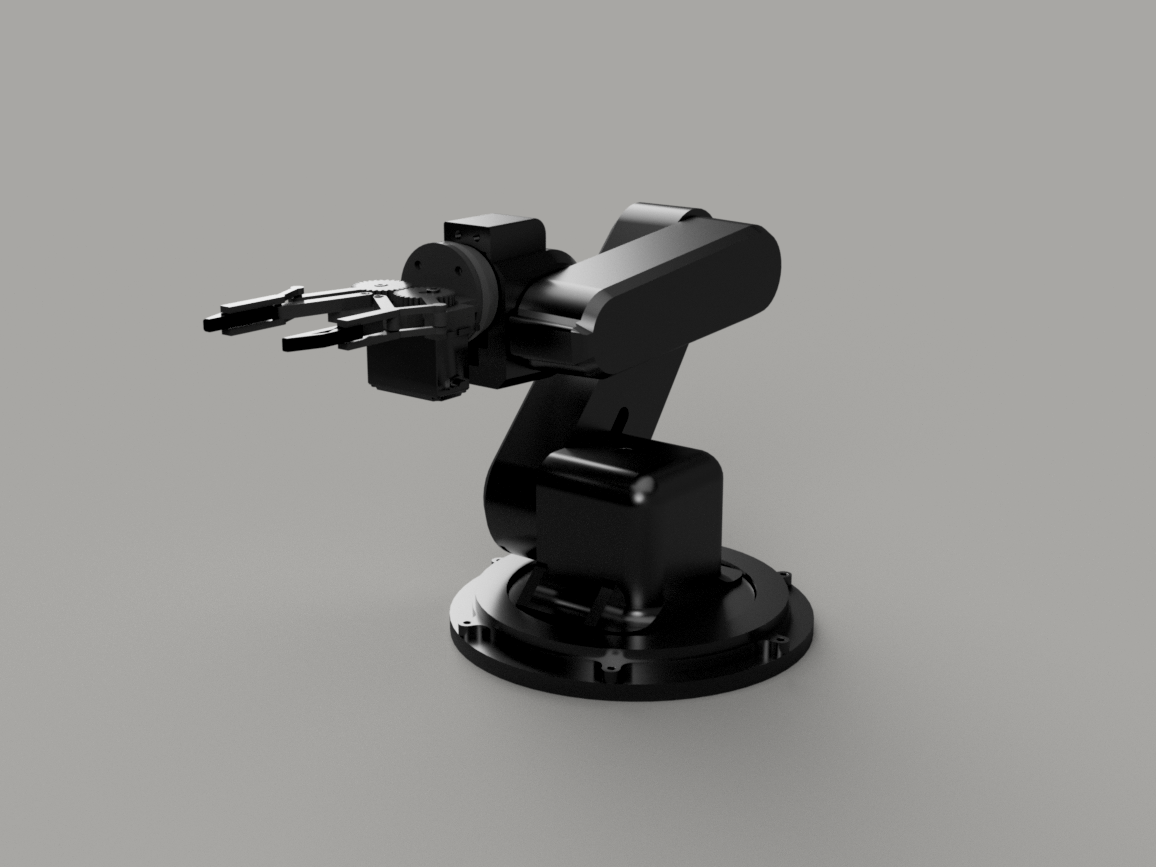
Built a 6-servo robotic arm from the ground up using an Arduino Uno and PCA9685 PWM servo driver. Designed in CAD and 3D printed, the arm combines mechanical design, electronics, and real-time software to execute precise assistive tasks in any workspace.
Technical Implementation:
· 6 servo motors mapped across PCA9685 channels (mix of standard and 360° continuous rotation)
· PWM/angle conversion with power-controlled smooth motion interpolation
· Serial command parsing interface for real-time arm control
· Forward kinematics-based collision boundary checking
· Homing routines and claw angle hard limits for safe operation
· Programmed demo sequences showcasing full range of motion
Results:
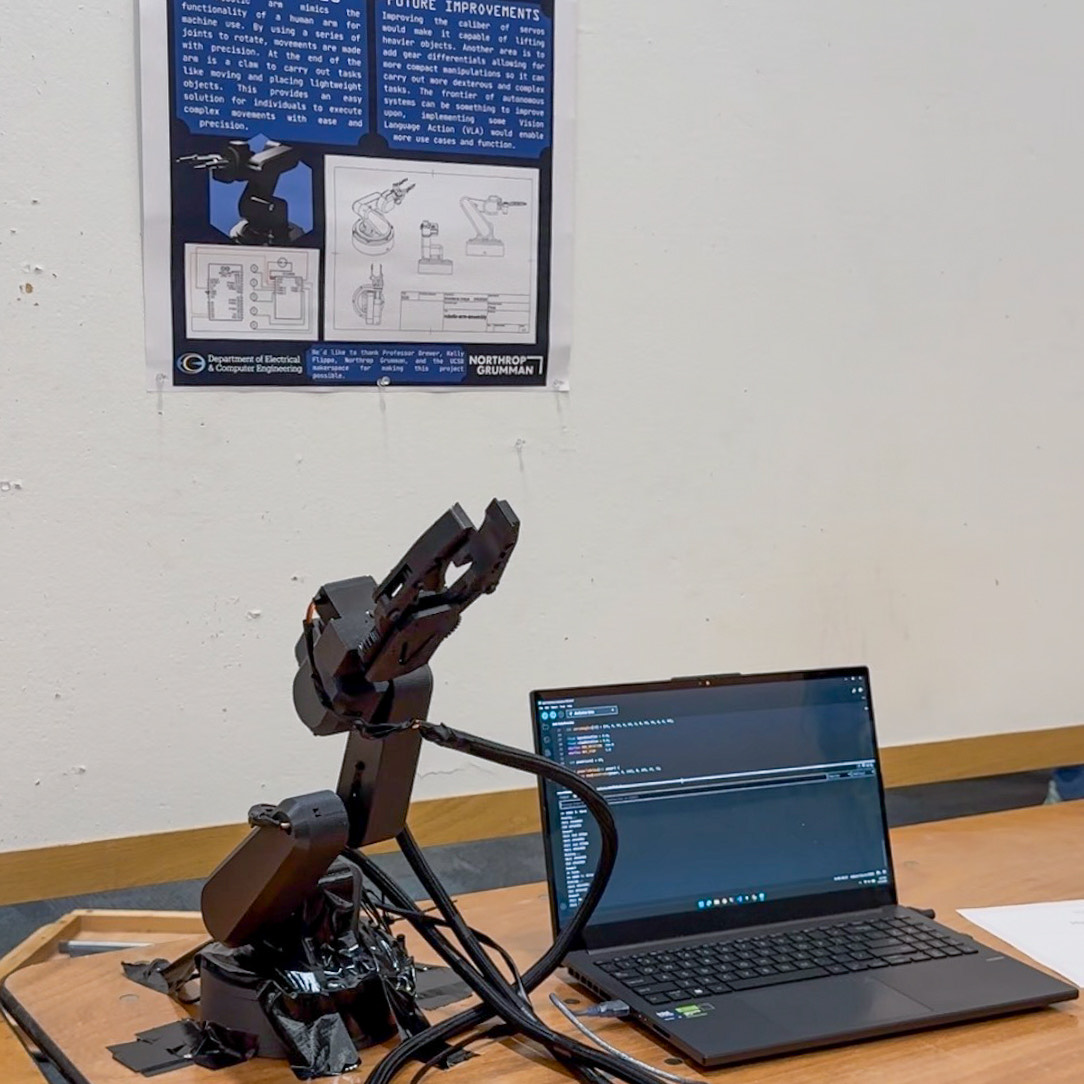
Successfully demonstrated precise multi-axis control with smooth, power-managed movement. ARM-01 was presented at the ECE Design Fair and recognized for its hardware complexity and build quality among 100 students (teams of 3).
Most Sophisticated Hardware Award — ECE Design Fair ·