Autonomous Robotic Car Project
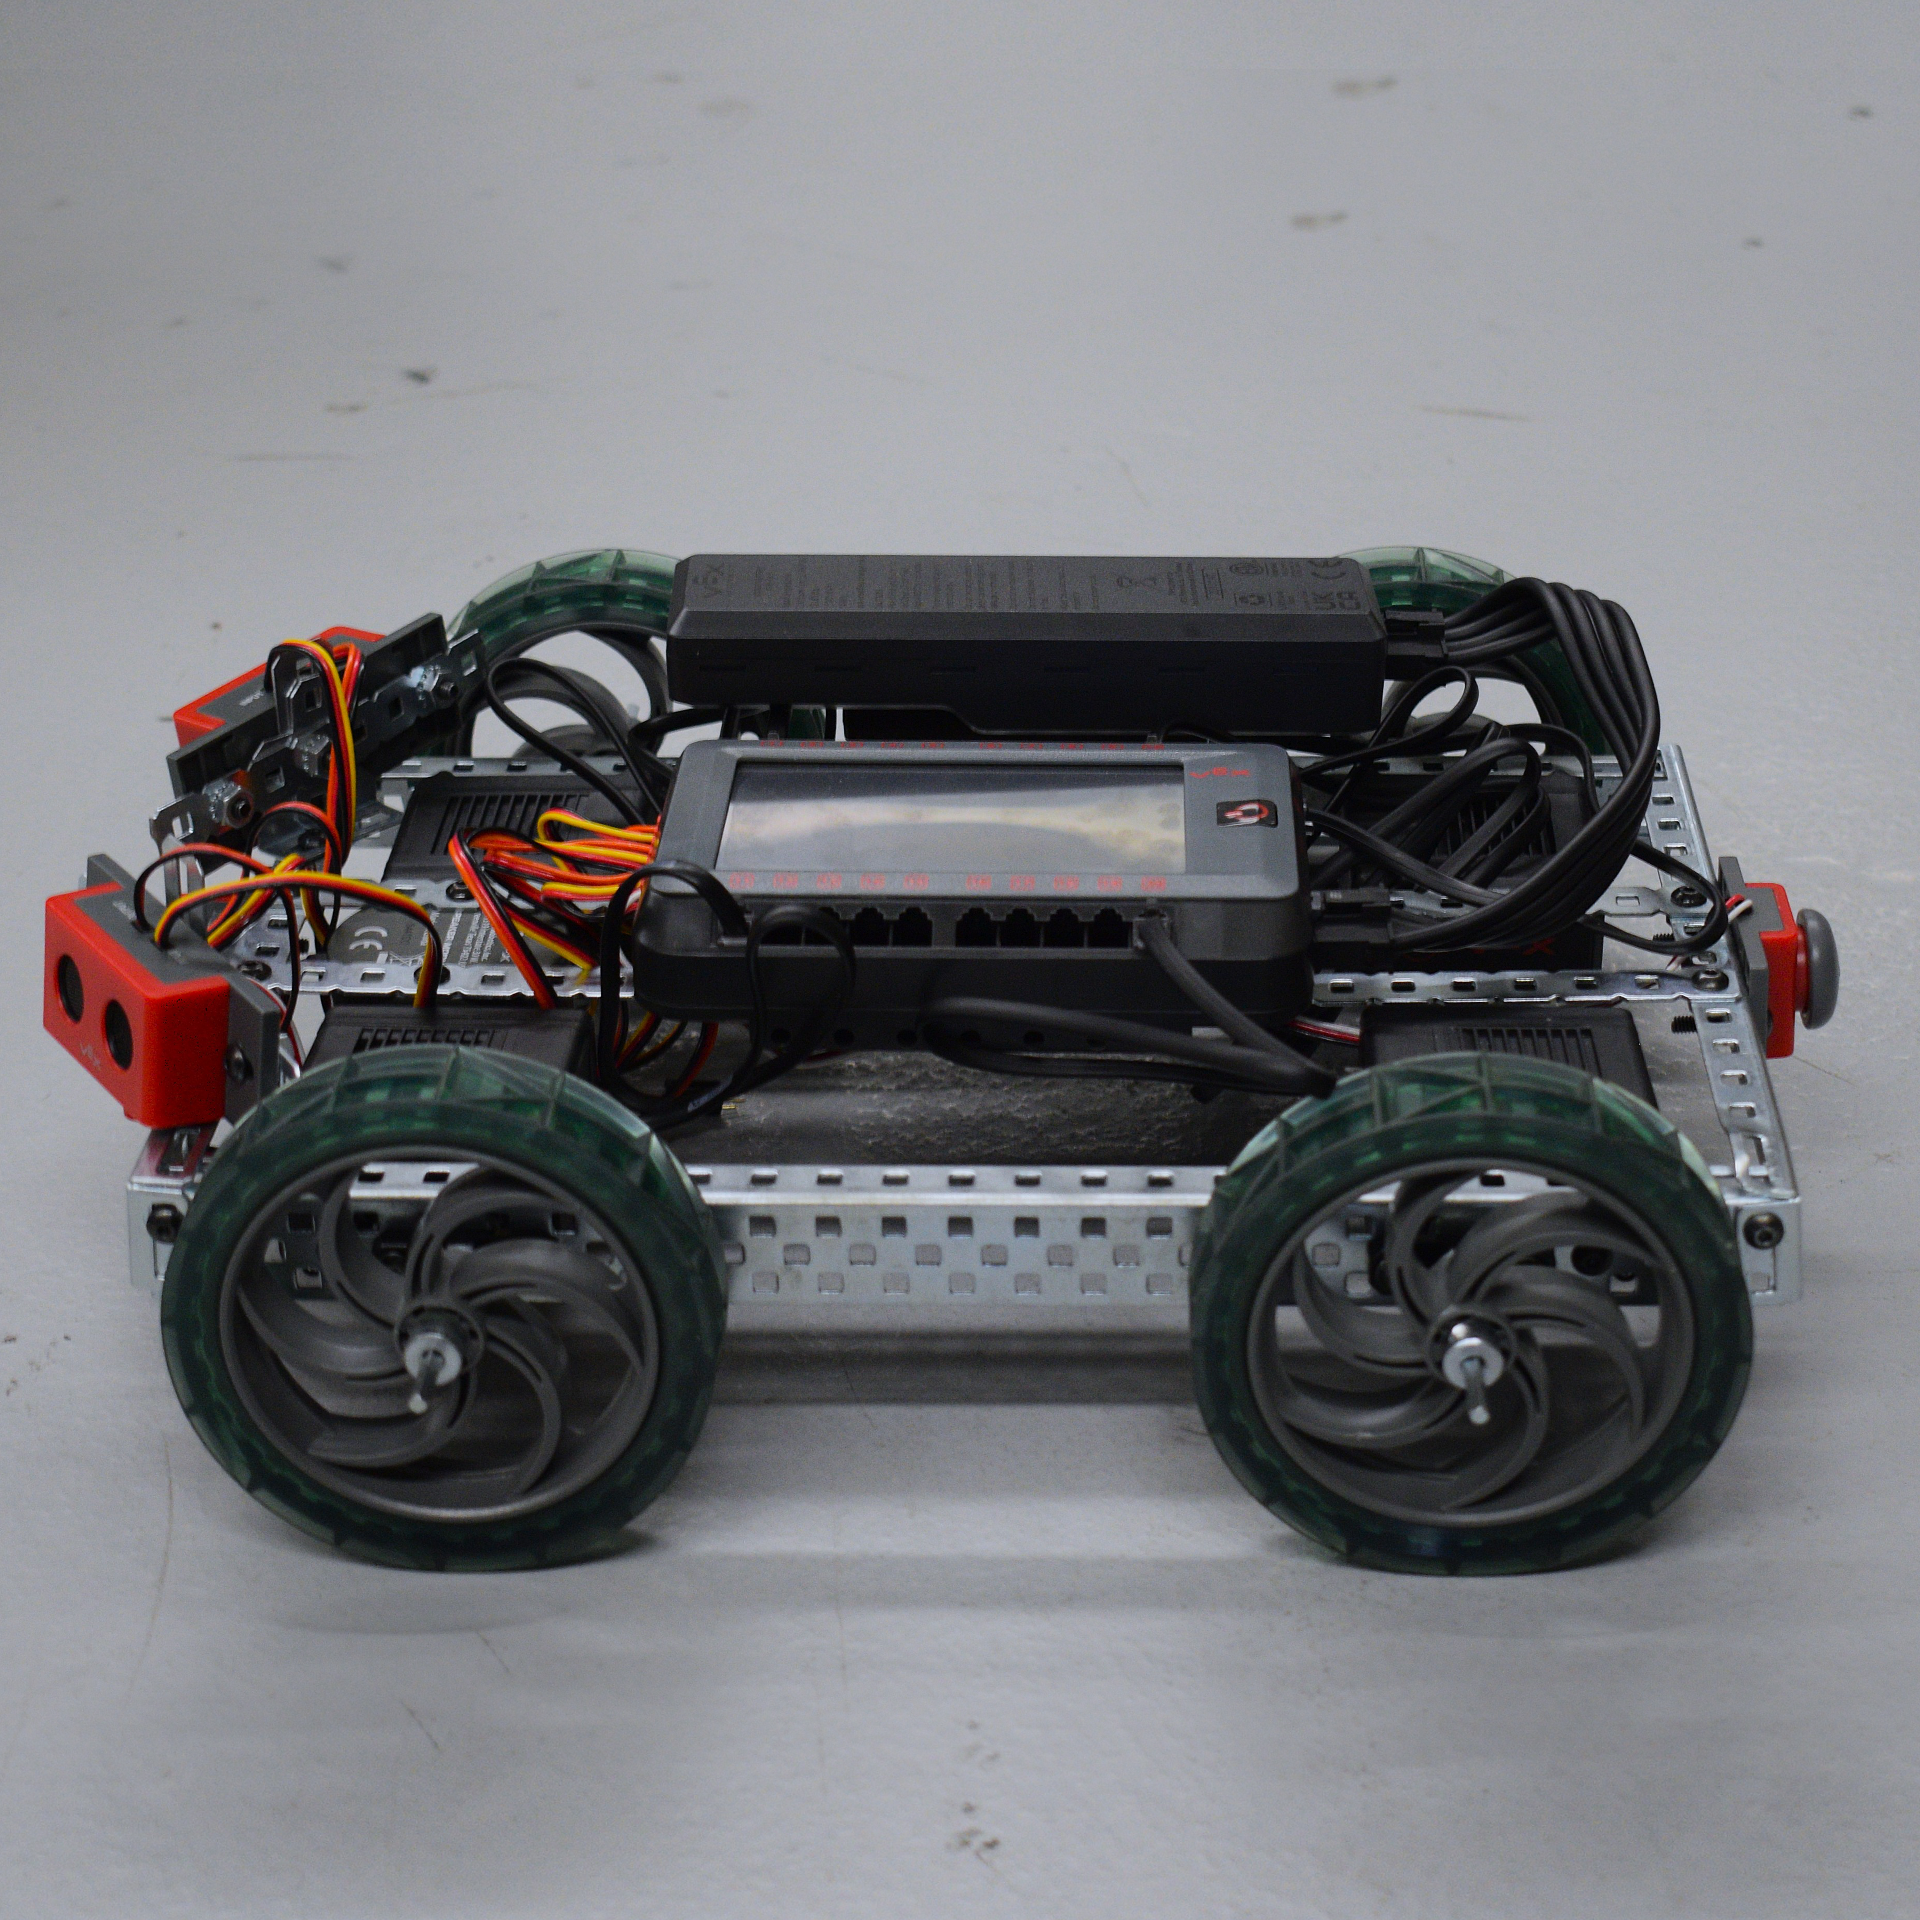
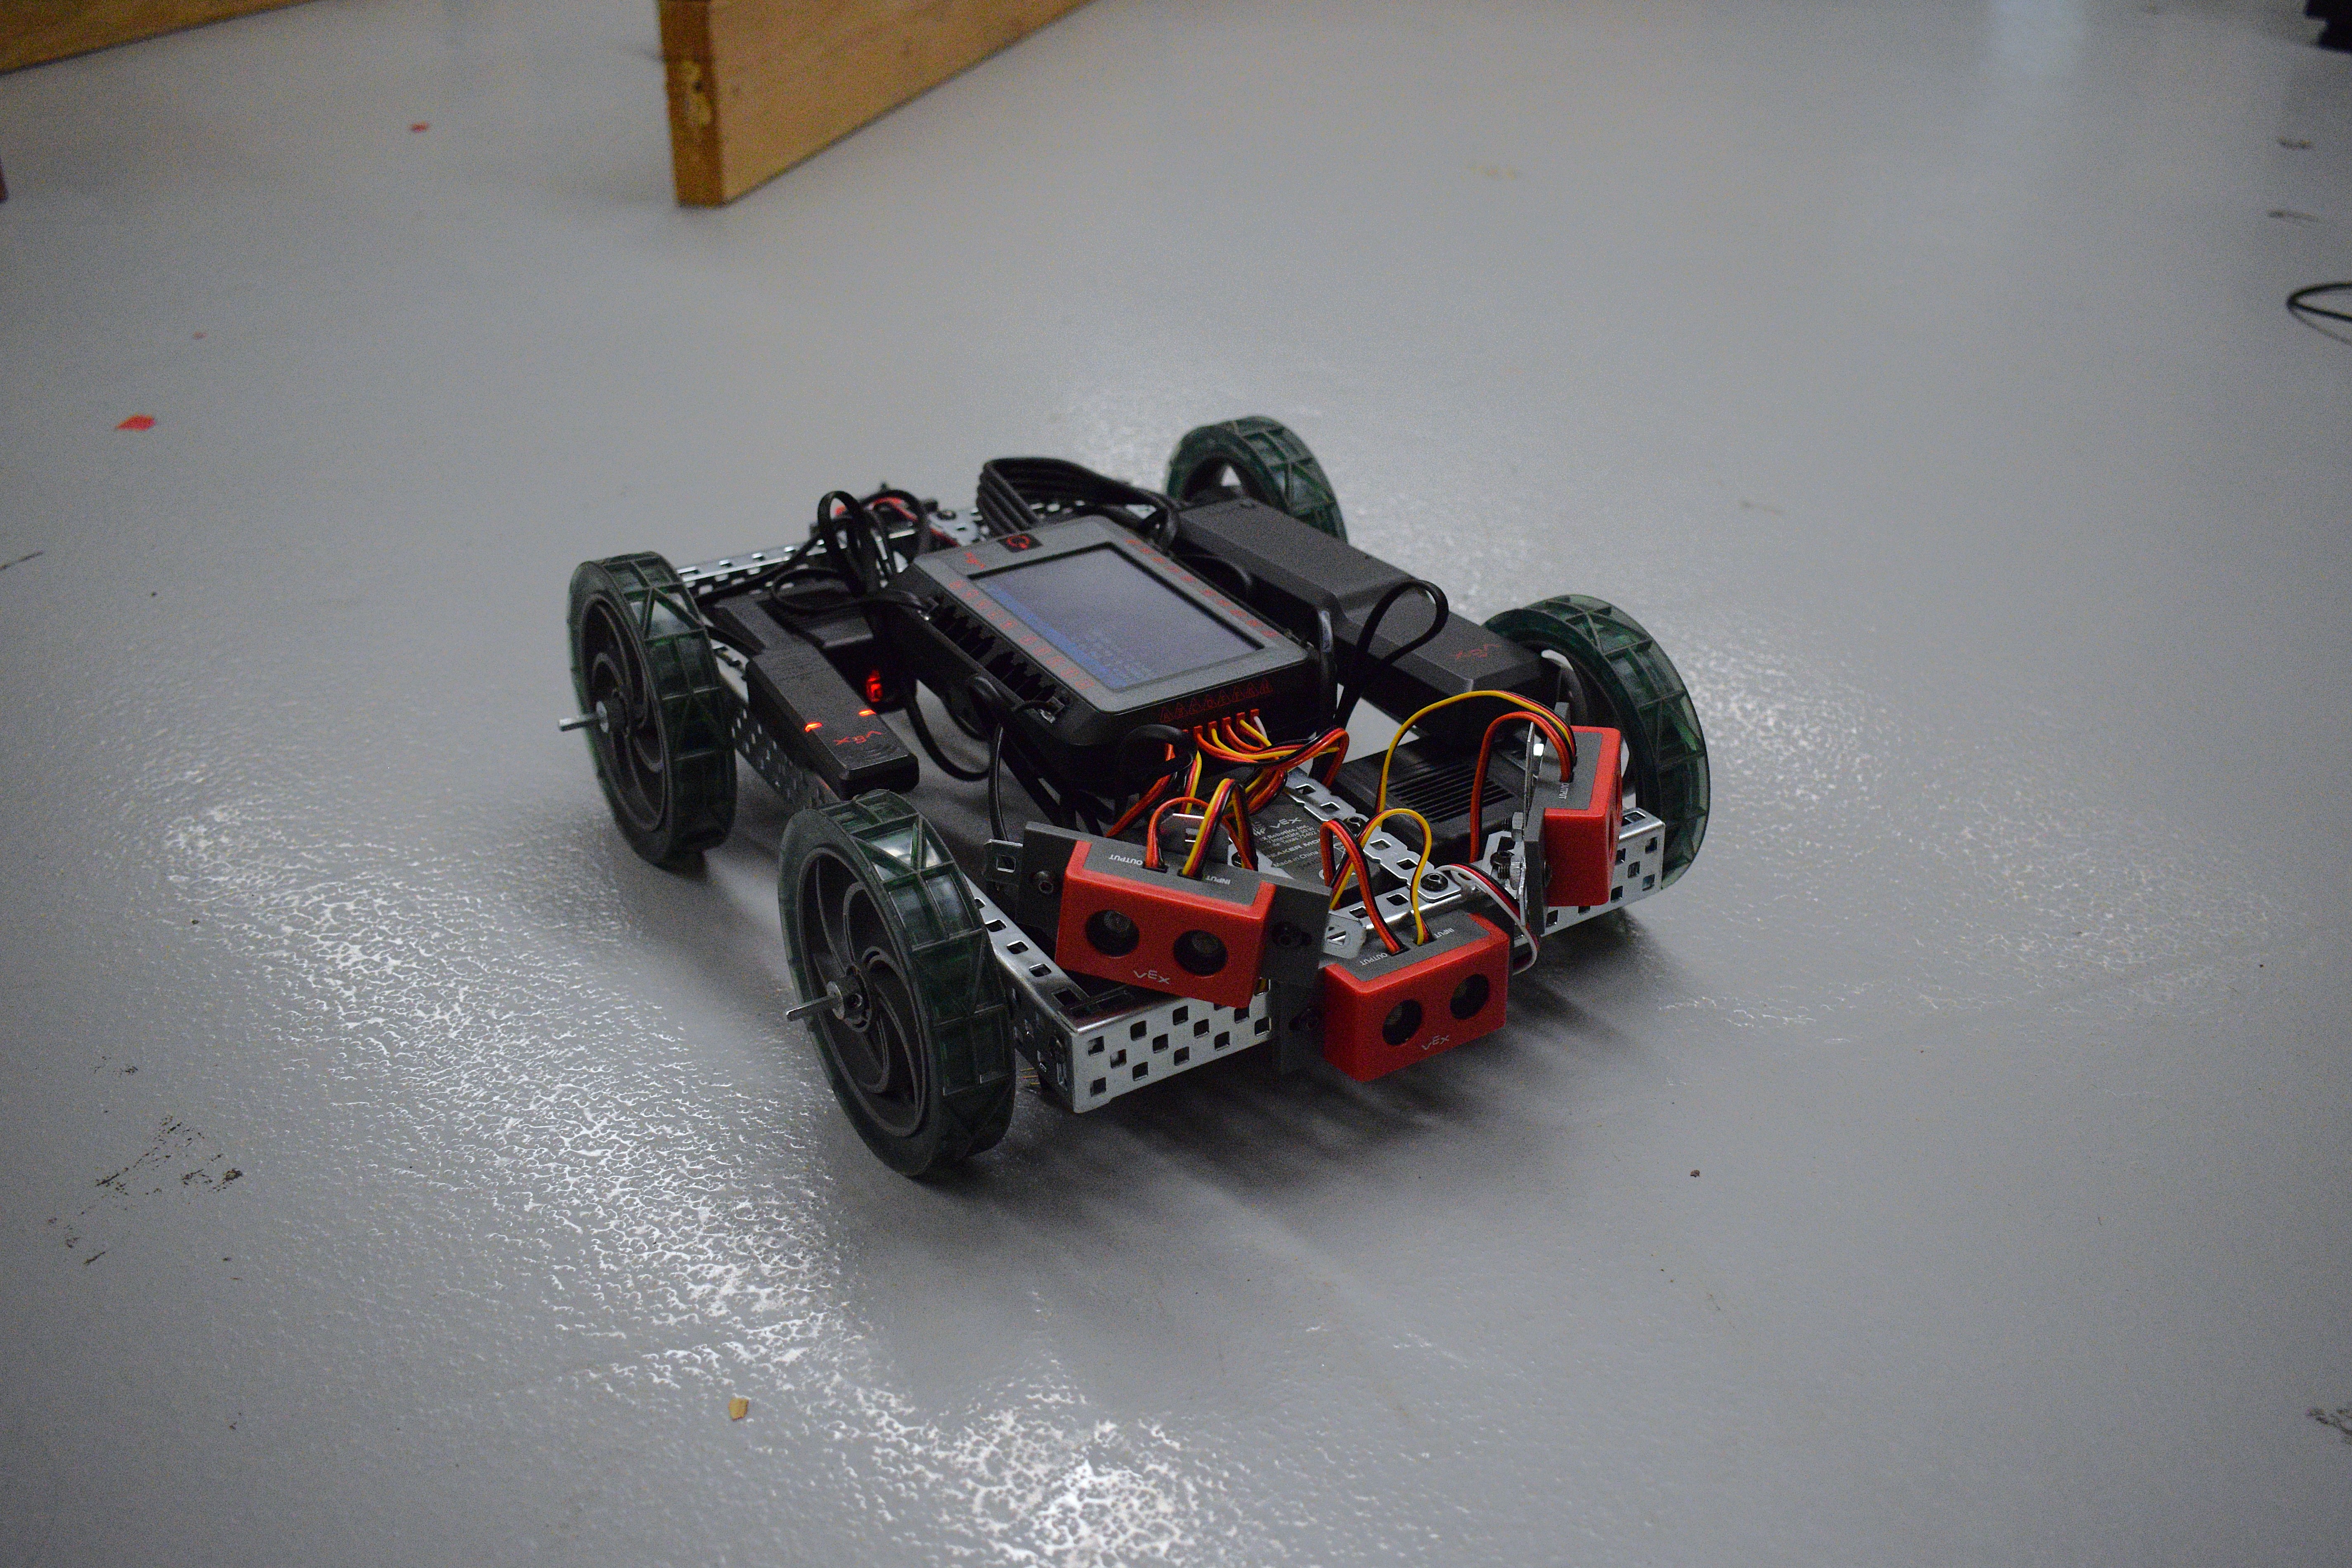
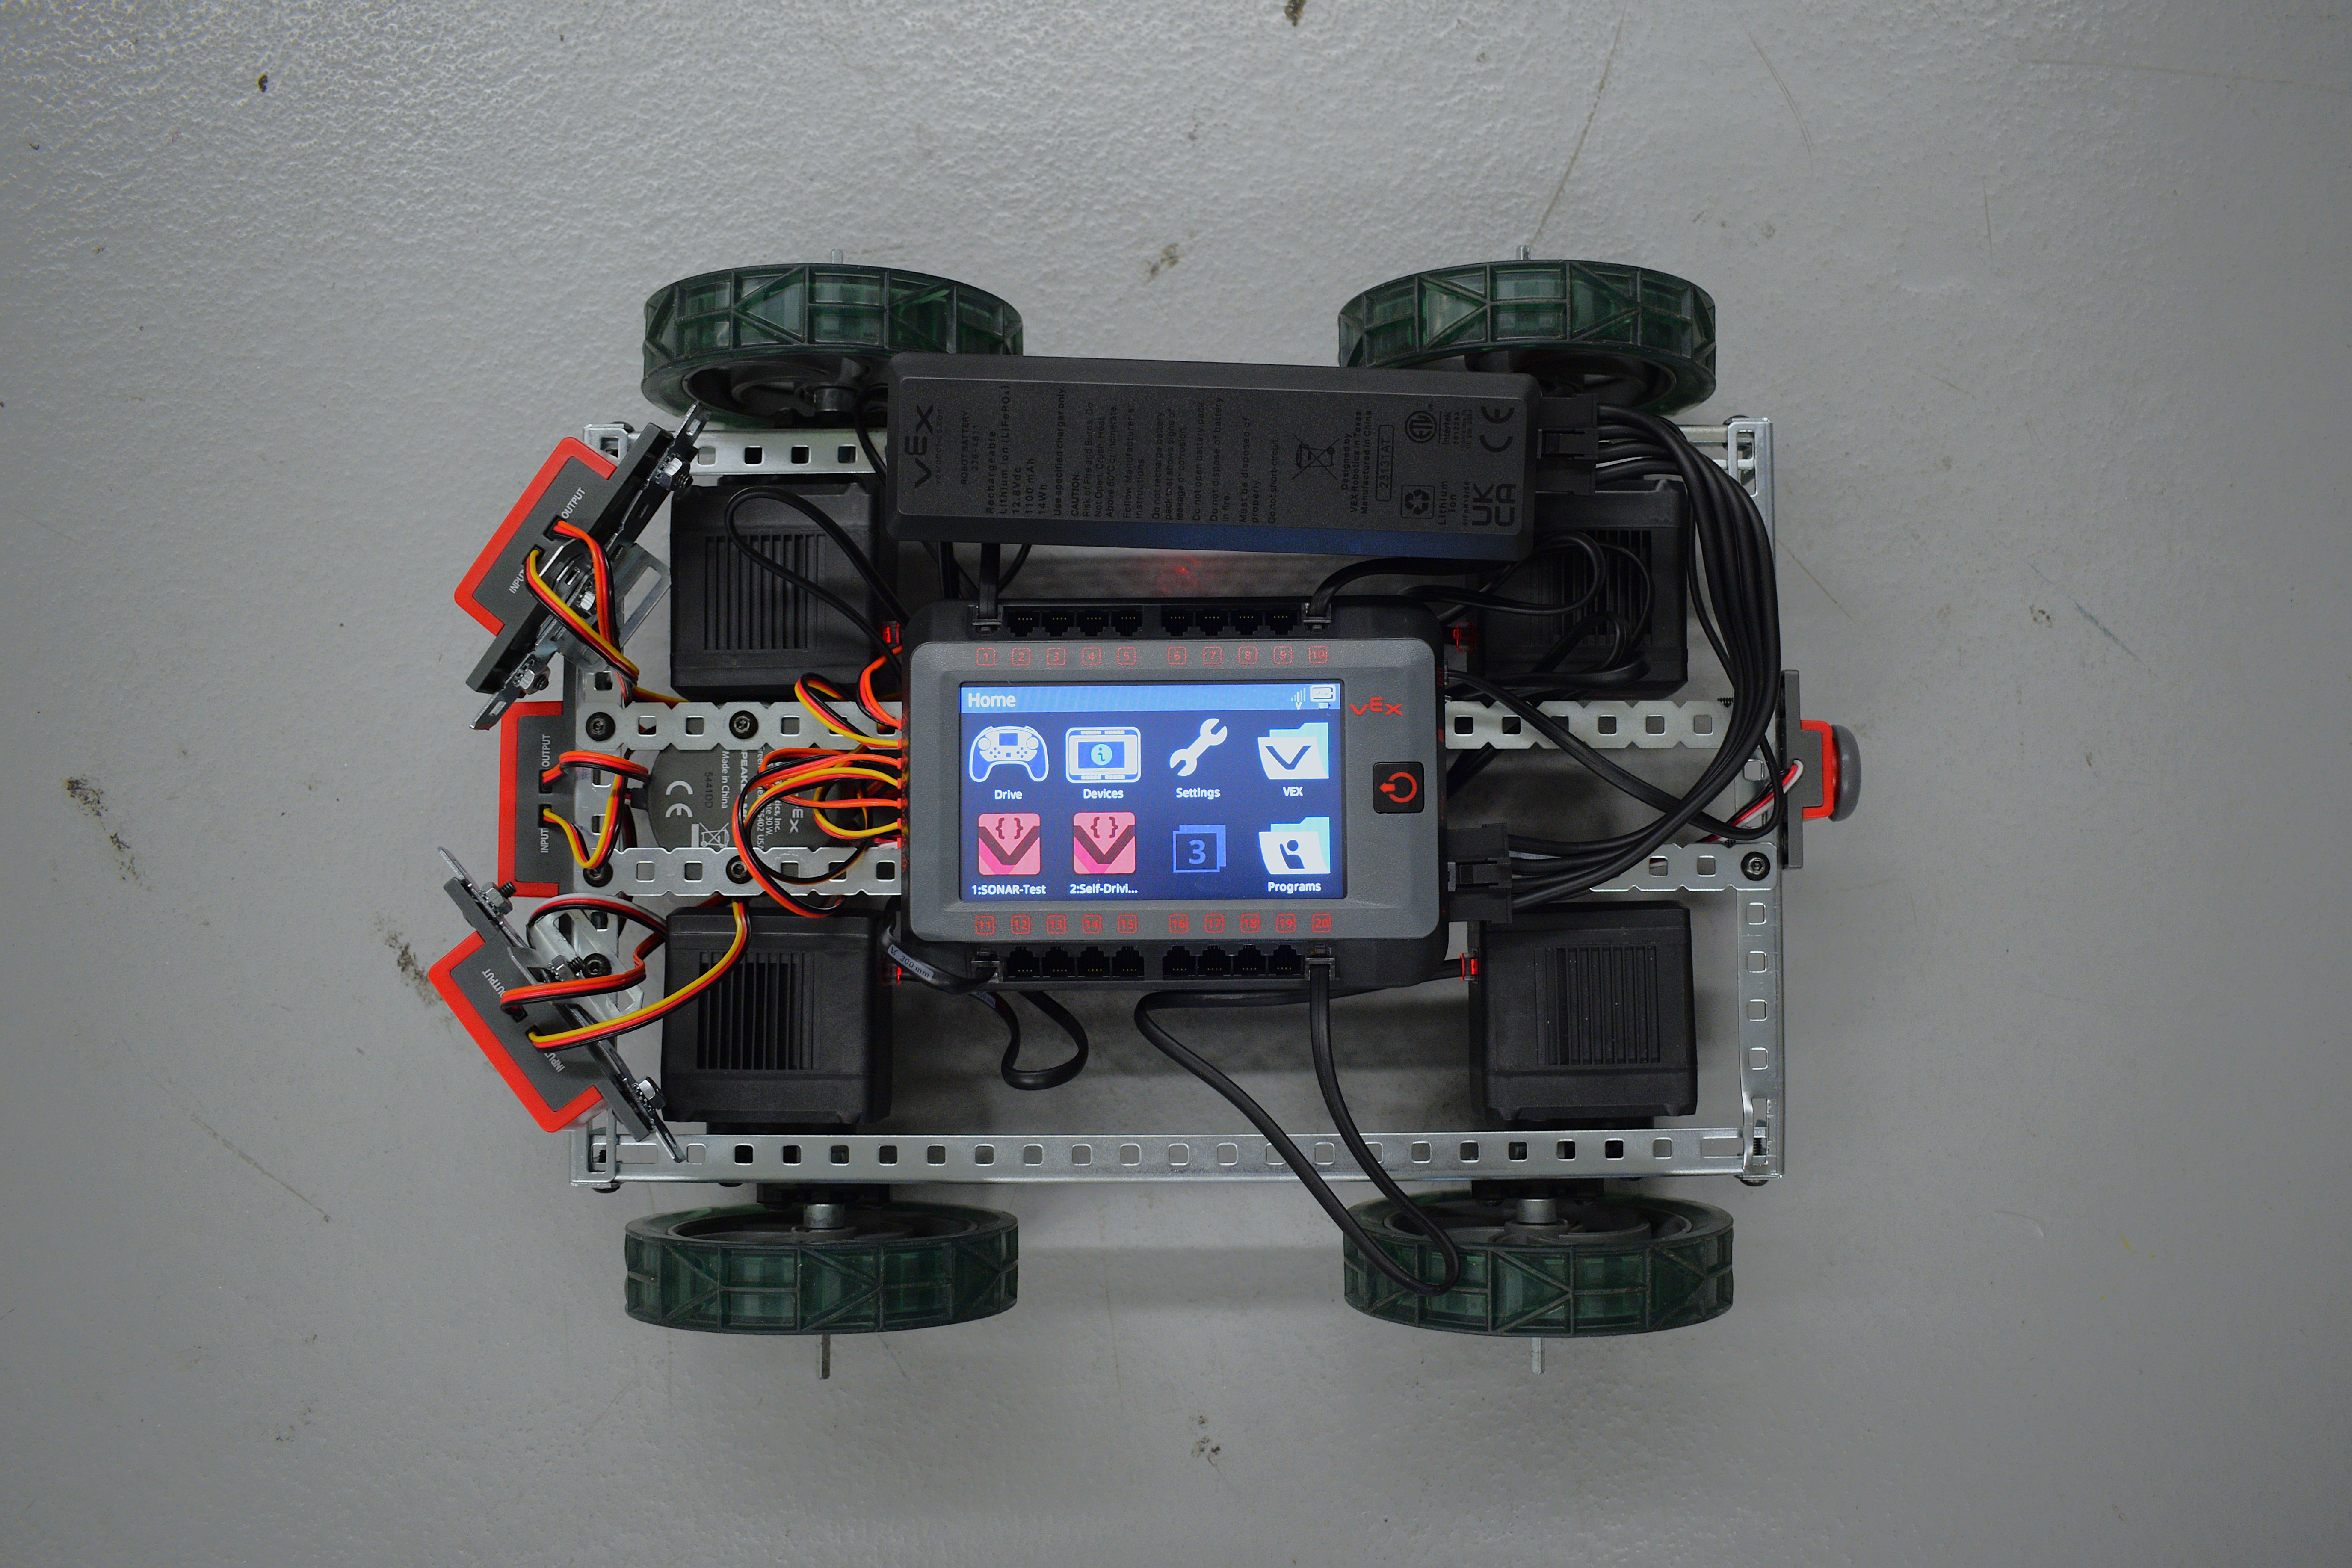
Built a self-navigating robot from the ground up using VEX V5 hardware and C++ programming. The system uses sensor fusion and real-time decision-making to autonomously traverse complex indoor environments.
Technical Implementation:
· Integrated three ultrasonic sensors for 135-degree obstacle detection and collision avoidance
· Developed navigation algorithms in C++ to process sensor data and execute pathfinding in real-time
· Optimized detection logic through iterative testing, increasing obstacle detection effectiveness by 200%
Results:
Achieved 95% navigation accuracy across various indoor environments Successfully demonstrated autonomous navigation through dynamic obstacle courses. This project reinforced my understanding of how hardware and sensor constraints directly shape algorithm design. Whether sensor refresh rates to the cortex processing limitations, every detail matters when building intelligent systems.